Build notes, programming updates, and stories from our team. Guaranteed updates every Saturday afternoon. Bonus updates might be dropped.
SURF ROBOTICS
From the workshop.
Website
Website update
A summary of some content added to our website since last time.
Read moreRead less
We have added a members only space (You don't need to know whats in there) and have some general other stuff related to the season throughout the website. Also we added a way for you to donate (please donate) to support us.
Hardware
Counterroller Test
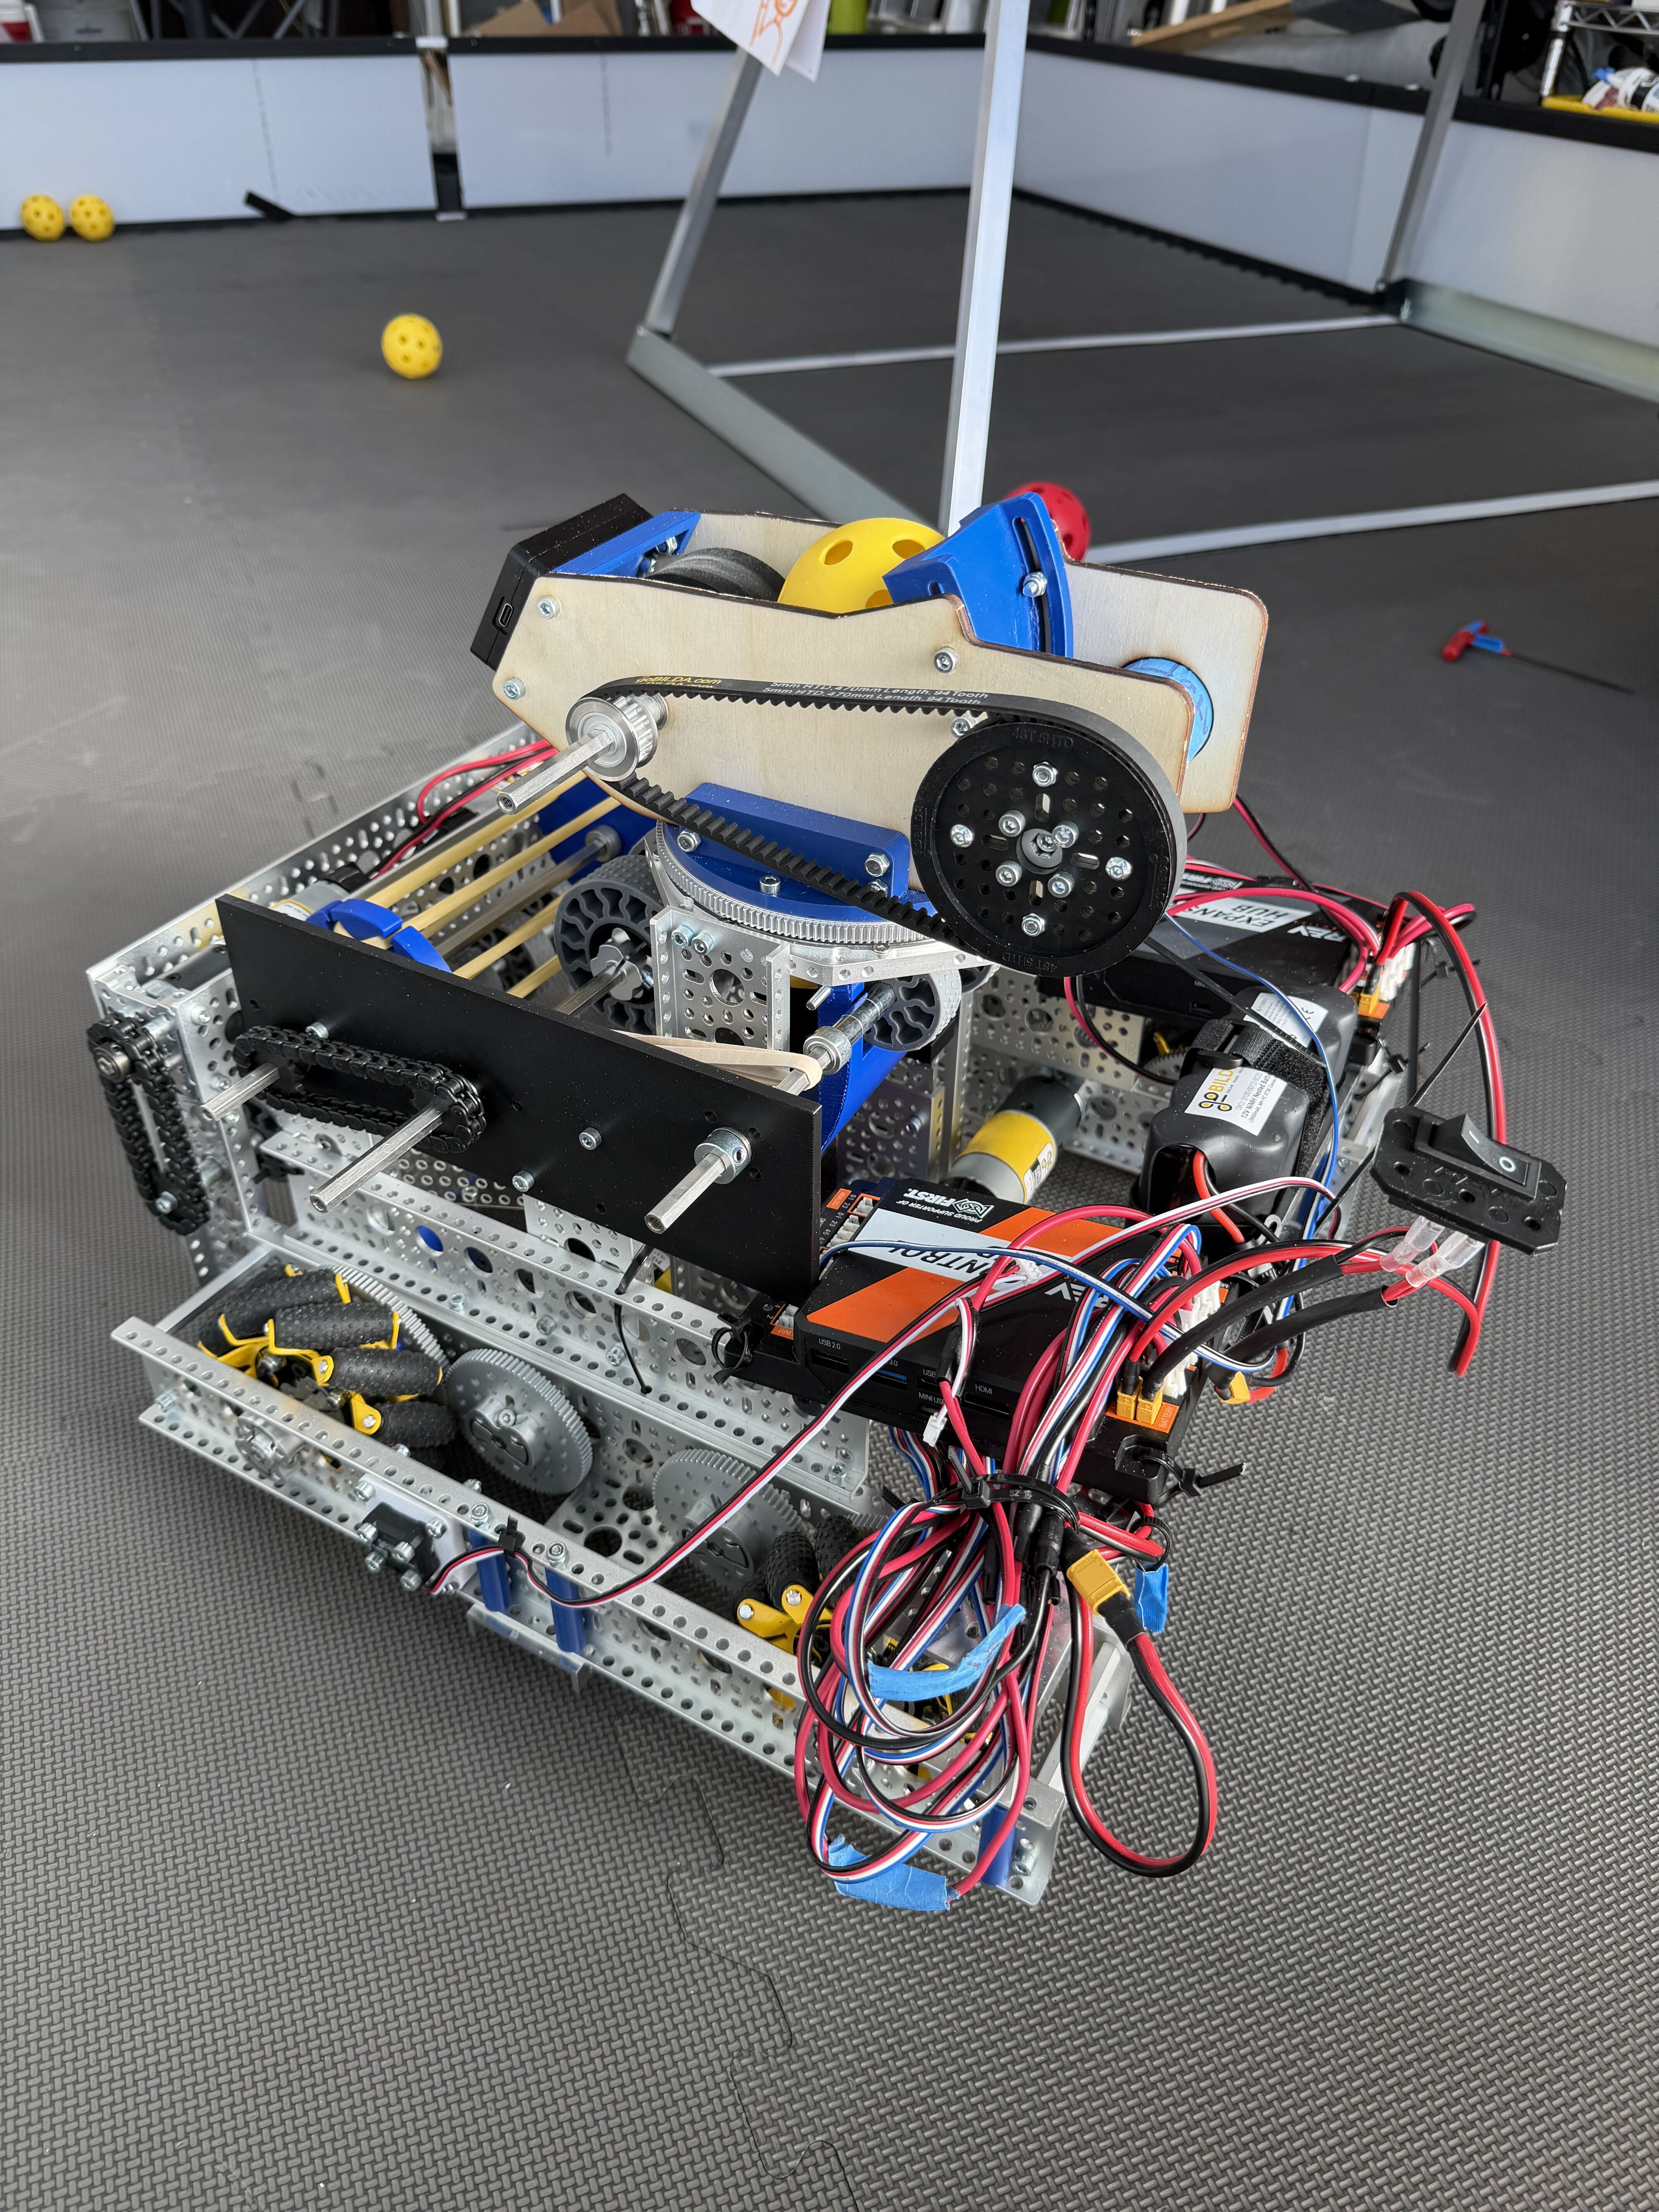
The semiformal shooter has been modified with an added counterroller (temporary). Additionally, we decided to disable the turret's turning, but a hardware issue forces the shooter to face backwards or else the balls cannot reach the flywheel.
Read moreRead less
We have added a temprorary counterroller on the shooter. It makes the pollens go in smoother. We also have ordered the parts needed for the second drivetrain today. The purpose of it was to change the backspin to topspin so the balls dont pop back out of the hive.
Hardware
Unamed Bot V4.1
Introducing Unamed Bot V4.1, which feautures a complete intake and shooting of pollen!
Read moreRead less
This robot features a complete intake, transfer, and shooting system. It still has some issues sometimes when intaking pollens. We will try to fix that.
The semiformal shooter has been built and is now ready.
Read moreRead less
Jason has created a semifinal shooter on our robot.
Hardware
Semiformal Shooter
A new semiforaml shooter has been built but is not ready yet.
Read moreRead less
Jason has created a semifinal shooter on our robot. Progress is very fast, the next step is to add counterrollers. We met today because our schools had no school. Unfortunately, the angle was not good so we will have more updates later.
Hardware
Transfer Prototype
The transfer prototype has been built by Isaac. We will mount it onto the drive train.
Read moreRead less
This transfer designed took a long time. It has a great result of transfering all pollens to the shooter.
Hardware
Shooter Prototype
The shooter now has a prototype, and it is working well.
Read moreRead less
Our shooter prototype design is probably going to be the final design. Stay tuned for more updates!
Hardware
Drive Train Assembly
New drive train has started assembling. We are currently printing stronger spacers.
Read moreRead less
The drive train should be functional by next Saturday.
Software
Basic Autonomous Movement Done
Basic autonomous movement is done, and it is the final version.
Read moreRead less
Our code features a fixed movement that allows the robot to collect pollens, and go to the correct shooting position.
Design
Design is Closer to Done
3D design of intake, and shooter are already done.
Read moreRead less
Our plan is to finish the full design by next Saturday.
Design
Drive Train Design Restarted
Jason and Isaac restarted designing the drive train.
Read moreRead less
We are almost done with the drive train design. The 3D design is still going.
Software
Apriltag Tracking and Driving Merged
We merged apriltag tracking and driving codes together. It worked.
Read moreRead less
The next step is to work on basic autonomous codes. We will share updates as we go on. The video only contains Apriltag tracking because the field has too less space for driving.
Hardware
Field Setup Arrived
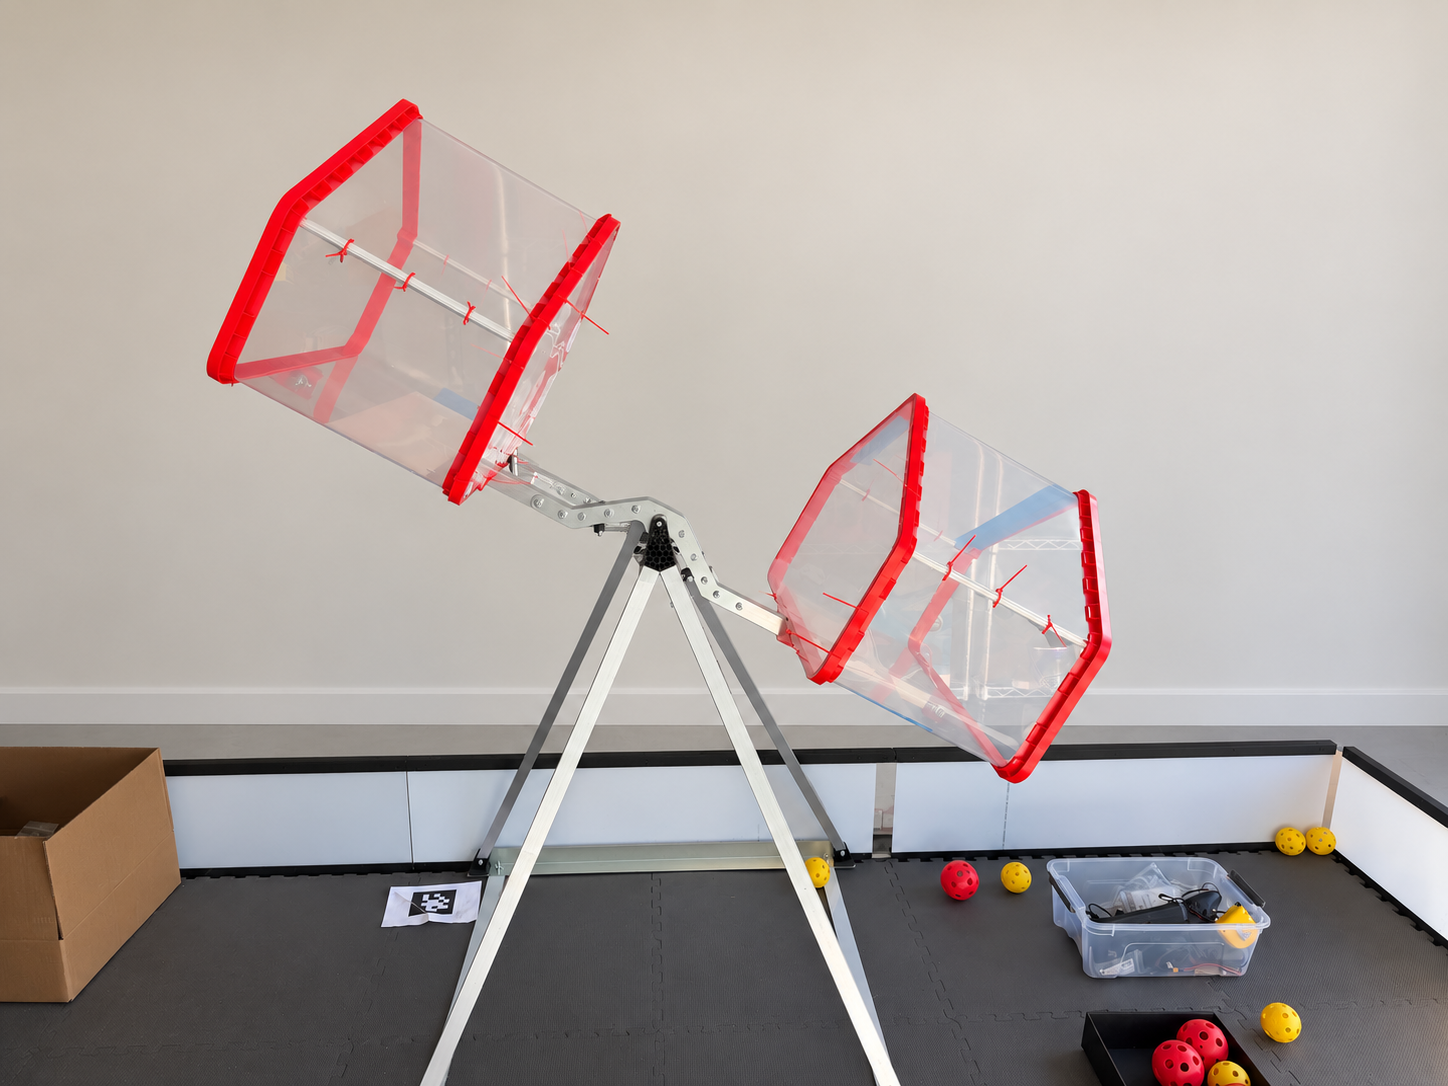
This year's BIOBUZZ field setup arrived today to us.
Read moreRead less
We finally get a chance to start testing our shooter (we don't have one yet).
Design
3D Design Delayed
Our 3D design that is expected to come out this Saturday got delayed.
Read moreRead less
We realized that our designs had some issues, which made us restart. We will continue to update on Saturdays.
Software
Apriltag Positioning Update
We got a apriltag detection and positioning code now. The next step is to test and debug.
Read moreRead less
Apriltag detection code is now complete, with a completed field-centric driving code. The next step is to code the basic autonomous code for shooting and positioning.
Design
New Robot Master Sketch
We fully finished our master sketch for our robot design on Onshape. It includes parts like intake, transfer, and a shooter.
Read moreRead less
The 3D design assembly will be done next week. We will share the final design with you.
Hardware
New Drive Train
Our new drive train was done on Thursday, September 17th and today. It includes timing belts and direct drives.
Read moreRead less
We have two drive trains, so that when one is taken down, the other one could be still used. The control hub is temporarily tied to the drive train. See engineering notebook 25 on the season page for details.
Website
Our Blog Came Back
On September 10, 2026, our blog finally came back after two months.
Read moreRead less
The blog was removed because of its high maintenance requirements, but it came back after we had time to restart it. We are excited to continue updating the blog as our season progresses.
Website
Our Blog Has a New Home
On July 2, 2026, our blog was successfully migrated to the engineering notebook.
Read moreRead less
The engineering notebook is the home for our detailed project records. This page will share highlights and team news as we continue building and learning.
Hardware
From an Idea to a Robot
We design and fabricate competitive robots using Onshape CAD and hands-on fabrication.
Read moreRead less
Our build updates will follow that process: the ideas we explore, the parts we make, and what we learn when we put them together.
We want to show the decisions behind the robot as well as the finished result.